 ☕️
Joint PhD Student · Research Intern
About Me
I am a joint PhD student at Harbin Institute of Technology (HIT) and Shanghai Innovation Institute (SII), and a research intern at RoboParty Lab. My research focuses on motion planning and control for legged and humanoid robots, with an emphasis on trajectory optimization, generative policies, and receding-horizon control.
I am interested in how the demands of a physical scene should shape a robot’s planning and control method: finding collision-free motions in confined spaces, choosing feasible contacts on sparse terrain, and turning flexible motion generation into reliable closed-loop execution.
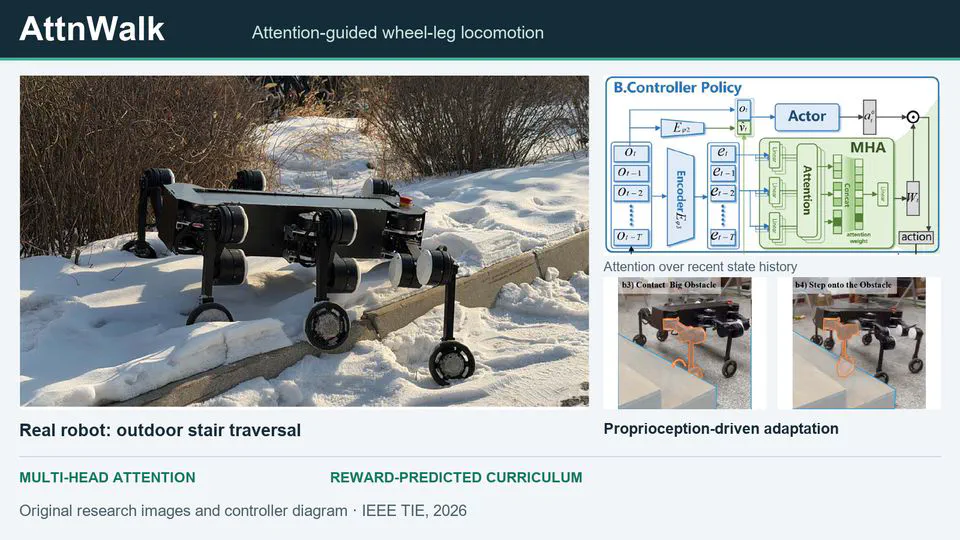
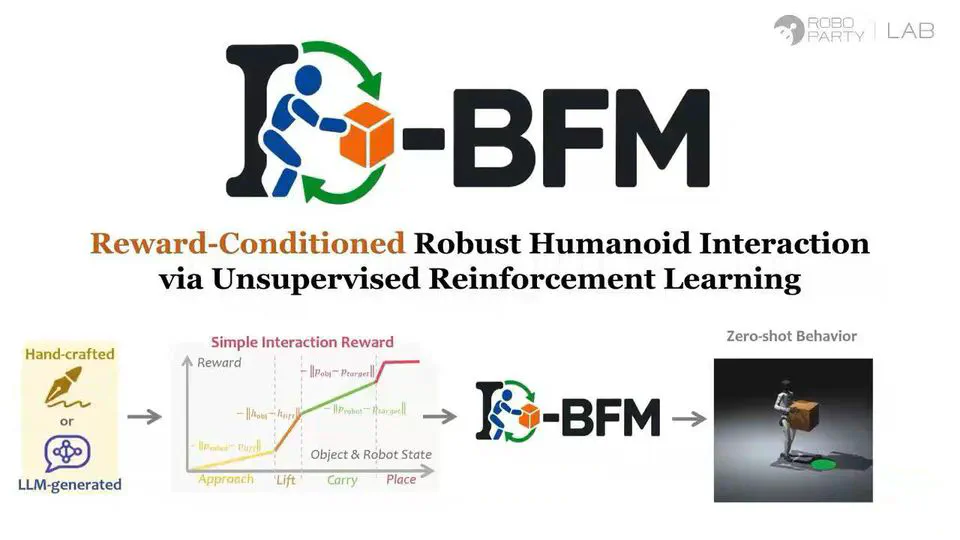
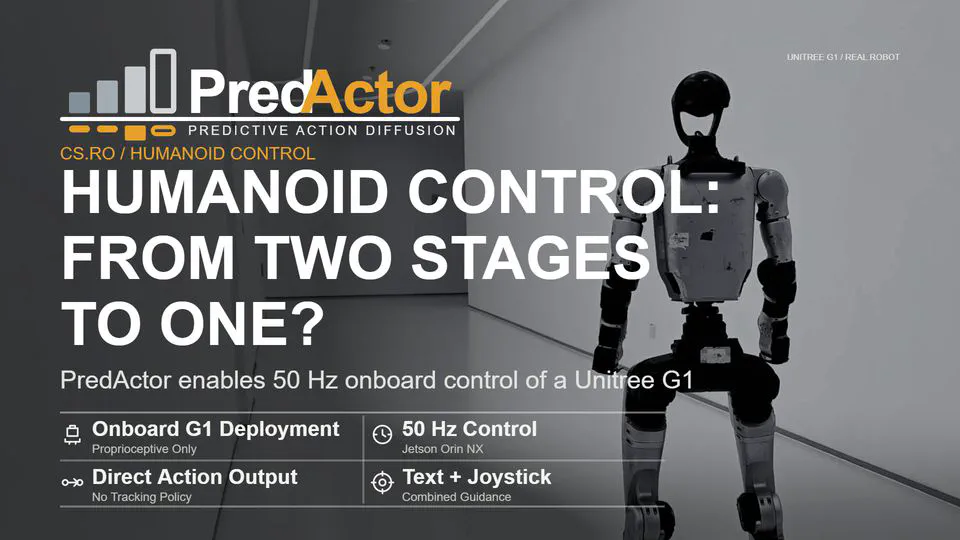
My work spans KCFRC, which analyzes kinematic and collision-aware foothold reachability, parallel MCTS contact planning under physical constraints, PegasusFlow, which samples trajectory score information directly from environmental interaction, and PredActor, which jointly generates future states and executable actions for onboard humanoid control. I also collaborate on AttnWalk for attention-based wheel-legged locomotion and I-BFM for reward-conditioned humanoid-object interaction.
Across these projects, I aim to connect geometric feasibility, environmental feedback, and learned behavior so robots can adapt their whole-body motion to changing tasks and surroundings. My work includes publications in IEEE Transactions on Industrial Electronics, IEEE Transactions on Robotics, and ICRA, alongside recent preprints on humanoid control.
- Legged and Humanoid Robotics
- Motion Planning and Control
- Trajectory Optimization
- Generative Policies and Receding-Horizon Control
PhD · Joint Program
Harbin Institute of Technology & Shanghai Innovation Institute
B.E. Automation
Harbin Institute of Technology


Experience
Research Intern
RoboParty LabGenerative humanoid control and whole-body interaction.
Education
PhD · Joint Program
Harbin Institute of Technology & Shanghai Innovation InstituteResearch on motion planning and control for legged and humanoid robots.B.E. Automation
Harbin Institute of TechnologyGPA: 96/100