Raymon Yip
  • Bio
  • Papers
  • Projects
  • Experience
  • Recent & Upcoming Talks
    • Example Talk
  • Publications
    • PredActor: Predictive Action Diffusion for Steerable Onboard Humanoid Control
    • KCFRC: Kinematic Collision-Aware Foothold Reachability Criteria for Legged Locomotion
    • PegasusFlow: Parallel Rolling-Denoising Score Sampling for Robot Diffusion Planner Flow Matching
    • AttnWalk: Attention-Enhanced Reinforcement Learning With Reward-Predicted Curriculum for Wheel-Legged Robots
    • I-BFM: Reward-Conditioned Robust Humanoid Interaction via Unsupervised Reinforcement Learning
    • Contact Planning for Multilegged Robots Under Constraints Through Parallel MCTS
  • Projects
    • Hexapod NMPC-WBC Controller
    • Hexapod Elevation Mapping
    • ChatPaper2Xmind
    • NotingDown
    • FOC Driver
    • Invoice Manager
    • SpaceSim Scene Editor
    • Ackermann Auto Parking
    • Automated Excavator
  • Projects
  • Blog
    • ๐ŸŽ‰ Easily create your own simple yet highly customizable blog
    • ๐Ÿง  Sharpen your thinking with a second brain
    • ๐Ÿ“ˆ Communicate your results effectively with the best data visualizations
    • ๐Ÿ‘ฉ๐Ÿผโ€๐Ÿซ Teach academic courses
    • โœ… Manage your projects
  • Experience
  • Teaching
    • Learn JavaScript
    • Learn Python

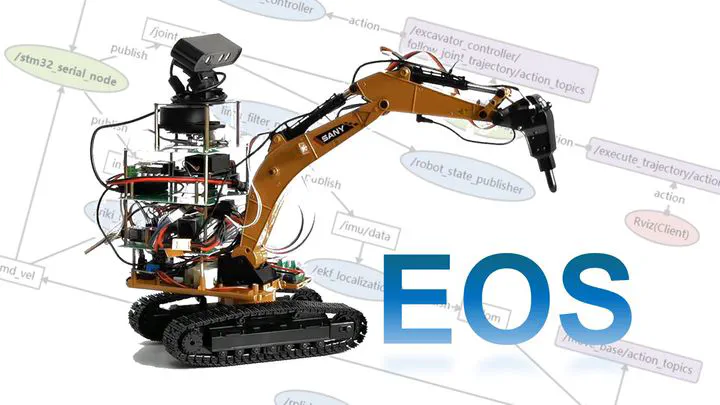
Automated Excavator

Sep 26, 2022 ยท 1 min read
Go to Project Site

A automated excavator adapted from SANY excavator model, using ROS and Gazebo for simulation and control.
Last updated on Sep 26, 2022
Robotics ROS
Lei Ye
Authors
Lei Ye
Joint PhD Student ยท Research Intern

← Ackermann Auto Parking Oct 23, 2022

ยฉ 2026 Raymon Yip. This work is licensed under CC BY NC ND 4.0

Published with Hugo Blox Builder โ€” the free, open source website builder that empowers creators.