PredActor: Predictive Action Diffusion for Steerable Onboard Humanoid Control

Lei Ye
Haibo Gao
Yitang Li
Peng Xu
Zetong Jing
Junhan Sun
Fanrong Dong
Ziqi Han
Xue Wang
Jianhua Sun
Cewu Lu
Hao Zhao
Liang Ding
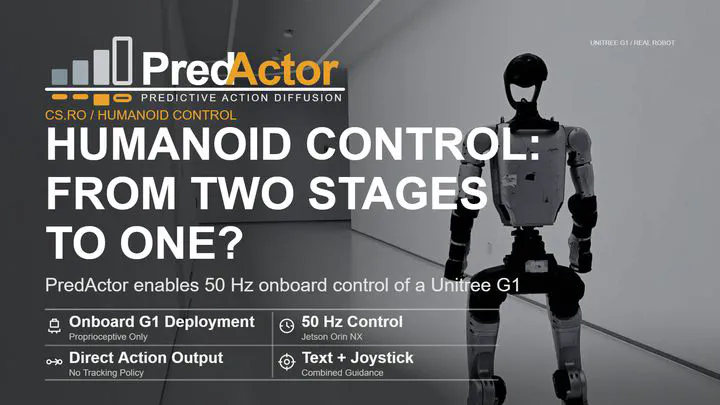 PredActor cover and Unitree G1 hardware photograph, supplied by the author.
Abstract
PredActor combines future-state prediction and direct action generation in one end-to-end diffusion policy. From proprioceptive history and optional task context, it predicts an internal state trajectory alongside executable actions. Classifier-free guidance strengthens text-conditioned behavior, while classifier guidance steers predicted states toward test-time objectives. Only the actions are executed; the state predictions remain inside the policy. Rolling denoising and runtime optimization enable 50 Hz onboard control on a Unitree G1 with a Jetson Orin NX. Simulation and hardware demonstrations cover text-conditioned motion, joystick steering, disturbance response, and semantic interpolation.
Type
Publication
arXiv preprint arXiv:2609.24840 (2026)
From motion generation to direct control
PredActor addresses the gap between flexible motion generation and closed-loop execution. A separate reference tracker is replaced by a policy that generates actions directly and uses its own future-state predictions as a guidance interface. Proprioceptive feedback closes the loop as inference rolls forward.
Steering one policy
- Text-conditioned behavior: classifier-free guidance strengthens the learned motion condition.
- Test-time objectives: classifier guidance steers internal predicted states, enabling joystick control and other motion objectives.
- Hardware execution: rolling denoising and computation-preserving runtime optimizations support a 20 ms control period on the onboard Jetson Orin NX.
The paper reports a measured complete callback latency of 16.790 ms median and 19.383 ms p95 on the Jetson Orin NX. Only generated actions are applied to the robot; predicted states remain inside the policy for guidance.
Project and demonstrations · Paper, version 3 · Released evaluation code